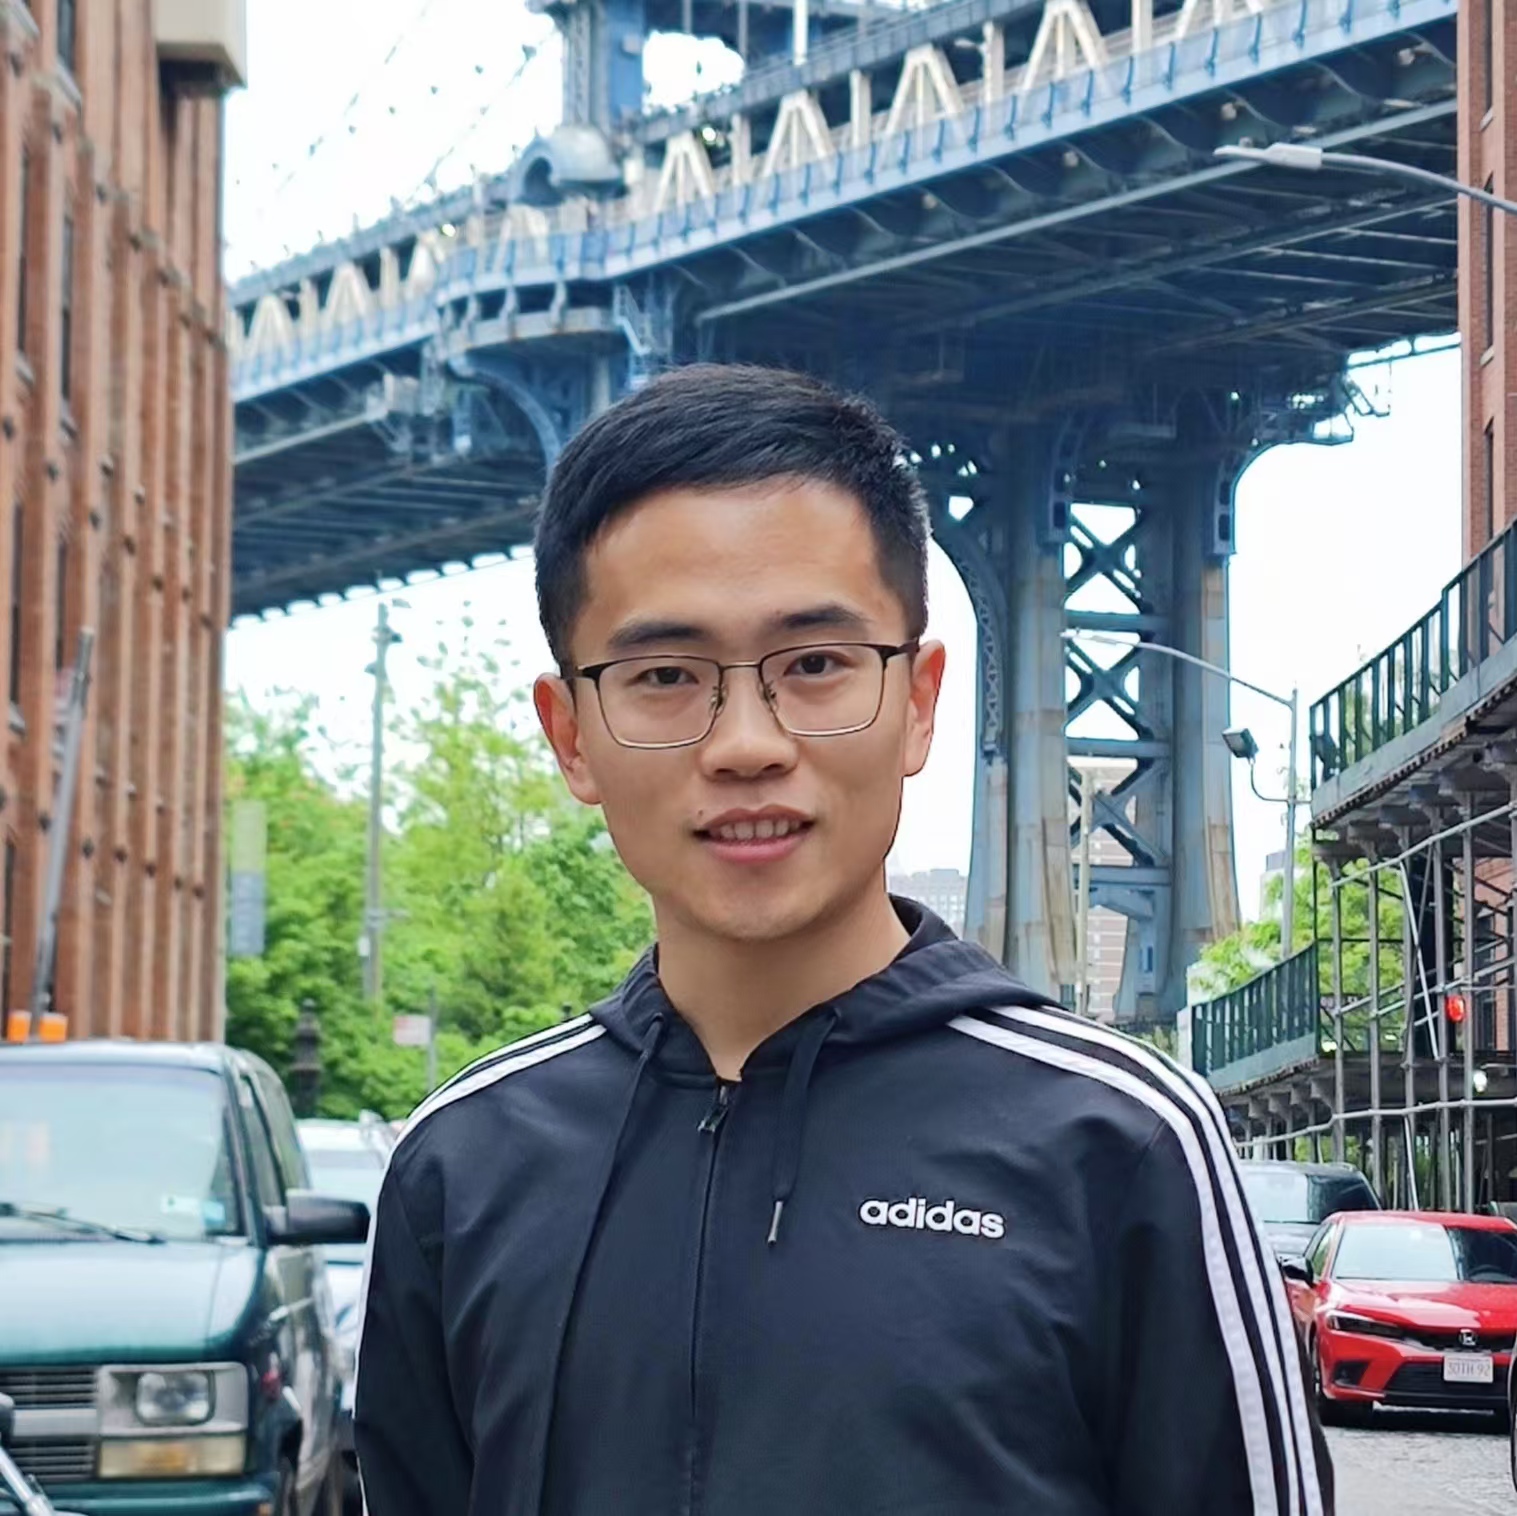
About me
Welcome! I’m Haichao Liu (刘海超), a Postdoctoral Research Fellow in the Perception and embodied INtElligence (PINE) Lab at the School of EEE, Nanyang Technological University, supervised by Prof. Ziwei Wang. My research develops embodied-intelligence and autonomous-driving systems that connect multimodal reasoning with decision-making, motion planning, control, and real-world robotic interaction.
I contribute to academic leadership and professional service as an area chair, senior reviewer, session chair/co-chair, committee member, and organizer of international robotics challenges. Previously, I was a visiting scholar at the National University of Singapore under Prof. Tong Heng Lee and a part-time research scientist with the Autonomous Systems and Robotics Group at A*STAR ARTC.
I received my PhD from The Hong Kong University of Science and Technology, advised by Prof. Jun Ma and Prof. Shaojie Shen. I earned my Master’s degree from Harbin Institute of Technology, supervised by Prof. Huijun Gao and Prof. Weiyang Lin, and my Bachelor’s degree in Robot Engineering from Northeastern University. I also participated in a Postgraduate Study Abroad Program at The University of Sydney.
I welcome research discussions and potential collaborations. Please feel free to contact me at haichao.liu@ntu.edu.sg.
🤖 SG EAI Challenge @ RoboSG! 2027
I invite students, researchers, and industry teams to participate in the Singapore Embodied AI Challenge for Manufacturing (SG EAI Challenge), which we are organizing at RoboSG! 2027 in Singapore!
Organized by Nanyang Technological University, A*STAR and the National Robotics Programme, with Micron Technology as title sponsor, the challenge invites teams to develop robotic assembly systems that bring perception, reasoning, planning and physical action together for manufacturing.
- 🧪 Online simulation phase: October 1 - December 31, 2026
- 📍 Onsite grand finals: March 20, 2027, Singapore, at RoboSG! 2027
- 🛠️ Resources: Simulation platform, baselines and datasets for development; standard robotic platforms provided at the onsite finals
- 🏆 Awards: Monetary awards for the top six teams; amounts and conditions will be confirmed in the official rules
If you work on dexterous manipulation, long-horizon reasoning or sim-to-real robot learning, join us and help advance embodied AI for manufacturing!
Quick links:
Research Interests
My research interests include the areas of Robotics and Autonomous Driving, with focus on:
- Dexterous Robot Manipulation with Open-vocabulary Commands,
- Decision-making, Planning and Control for Autonomous Driving,
with the following technologies:
- Large Multimodal Language Models,
- Reinforcement learning and imitation learning,
- Convex and non-convex optimization.
Academic and Professional Service
- Peer Reviewer: The International Journal of Robotics Research (IJRR), IEEE Transactions on Cybernetics, IEEE Transactions on Intelligent Transportation Systems, IEEE Transactions on Vehicular Technology, IEEE RA-L, Nature-Discover Robotics, IEEE Robotics and Automation Magazine, Journal of Field Robotics, Aerospace Science and Technology, PLOS ONE, Robotics: Science and Systems (RSS), ICRA, IROS, IV Symposium, ITSC, ROBIO, IECON, etc.
- Senior Reviewer: IEEE Robotics and Automation Society Young Reviewer Program (YRP)
- Session Chair/Co-Chair: ITSC 2025, IROS 2025, IROS 2026
- Area Chair: EIR 2026
- Committee Member: AIAAT 2026 (Kunming, China), AMLDS 2026 (Osaka, Japan), AMLDS 2027 (Aizu-Wakamatsu, Japan)
- Overall PiC for 1st Robotic Collaborative (RoCo) Assembling Challenge for Human-Centered Manufacturing at AAAI 2026
- Organizer of the 2nd Robotic Collaborative Assembly (RoCo) Challenge at IROS 2026 (September 27 - 30, 2026, Pittsburgh, USA)
- Other Services:
- President of NTU EEE Research Staff Association (RSA)
- Vice President of HKUST-GSAA
Publications
Featured Publications
DexTeleop-0: Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy
H. Liu, Y. Jiang, H. Park, Y. Xue, Z. Wang, "DexTeleop-0: Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy," arXiv preprint arXiv:2606.23431, 2026.
UniManip: General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph
H. Liu, Y. Xue, Y. Zhou, H. Deng, Y. Liang, L. Xie, Z. Wang, "UniManip: General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph," arXiv preprint arXiv:2602.13086, 2026.
RoCo Challenge at AAAI 2026: Benchmarking Robotic Collaborative Manipulation for Assembly Towards Industrial Automation
H. Liu, Y. Zhou, Z. Wu, Z. Ji, Z. Shan, Q. Wang, R. Liu, Z. Yang, Y. Gu, S. Khan, S. Yan, J. Liu, H. Zhu, C. Liu, J. Yang, J. Zhang, Z. Wang, "RoCo Challenge at AAAI 2026: Benchmarking Robotic Collaborative Manipulation for Assembly Towards Industrial Automation," arXiv preprint arXiv:2603.15469, 2026.
RoboDexVLM: Visual Language Model-Enabled Task Planning and Motion Control for Dexterous Robot Manipulation
H. Liu, S. Guo, P. Mai, J. Cao, H. Li, and J. Ma, "RoboDexVLM: Visual Language Model-Enabled Task Planning and Motion Control for Dexterous Robot Manipulation," in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025, pp. 1-8.
LMMCoDrive: Cooperative Driving with Large Multimodal Models
H. Liu, R. Yao, Z. Huang, S. Shen, and J. Ma, "LMMCoDrive: Cooperative Driving with Large Multimodal Model," in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025, pp. 1-8.
UDMC: Unified Decision-Making and Control Framework for Urban Autonomous Driving with Motion Prediction of Traffic Participants
H. Liu, K. Chen, Y. Li, Z. Huang, M. Liu, and J. Ma, "UDMC: Unified Decision-Making and Control Framework for Urban Autonomous Driving with Motion Prediction of Traffic Participants," IEEE Transactions on Intelligent Transportation Systems, , vol. 26, no. 5, pp. 5856-871, 2025.
Improved consensus ADMM for cooperative motion planning of large-scale connected autonomous vehicles with limited communication
H. Liu, Z. Huang, Z. Zhu, Y. Li, S. Shen, and J. Ma, "Improved consensus ADMM for cooperative motion planning of large-scale connected autonomous vehicles with limited communication," IEEE Transactions on Intelligent Vehicles, vol. 9, no. 11, pp. 7222-238, 2024.
Complete Publication List
All Papers
UniIntervene: Agentic Intervention for Efficient Real-World Reinforcement Learning
H. Deng, Y. Gao, Y. Lin, H. Liu, Z. Wu, Z. Wang, "UniIntervene: Agentic Intervention for Efficient Real-World Reinforcement Learning," Proceedings of the Conference on Robot Learning (CoRL), 2026.
RATE: Risk-Aware Tactile Encoding for Contact-rich Robotic Manipulation
Y. Jiang, H. Liu, J. Zheng, Z. Ding, W. Yuan, Z. Wang, "RATE: Risk-Aware Tactile Encoding for Contact-rich Robotic Manipulation," arXiv preprint arXiv:2610.03538, 2026.
Facet-0: A Robotic Foundation Model for Contact-Rich Precise Manipulation
H. Deng, H. Liu, W. Guo, Y. Ling, Z. Yang, Y. Xue, H. Sun, L. Wang, Z. Wang, "Facet-0: A Robotic Foundation Model for Contact-Rich Precise Manipulation," arXiv preprint arXiv:2609.01596, 2026.
Tac4Loco: Learning Spatiotemporal Plantar Pressure Representations for Humanoid Locomotion
Z. Liu, S. Guo, Z. Li, J. Cao, H. Liu, P. Qu, Y. Zhang, J. Zhou, J. Ma, "Tac4Loco: Learning Spatiotemporal Plantar Pressure Representations for Humanoid Locomotion," arXiv preprint arXiv:2608.15766, 2026.
Effects of Environmental Perception and Planned Maneuver Visualization on Takeover Performance in Silent Failure Scenarios
S. Yan, H. Liu, J. Zhang, J. Wang, J. Ma and D. He, "Effects of Environmental Perception and Planned Maneuver Visualization on Takeover Performance in Silent Failure Scenarios," International Journal of Human - Computer Studies, vol. 0, no. 0, pp. 1-34, 2026.
Potential-Game Structured Cooperative Eco-Driving for Mixed Platoons at Signalized Intersections
J. Fan, H. Liu, Y. Zou, W. Liu, and J. Ma, "Potential-Game Structured Cooperative Eco-Driving for Mixed Platoons at Signalized Intersections," Unmanned Systems, vol. 0, no. 0, pp. 1-18, 2026.
Behavioral Uncertainty-Aware Attention Allocation via VLMs for Interactive Autonomous Driving
B. Ma, H. Liu, R. Zhong, P. Liu, X. Zhou, and J. Ma, "Behavioral Uncertainty-Aware Attention Allocation via VLMs for Interactive Autonomous Driving," IEEE Transactions on Vehicular Technology, vol. 0, no. 0, pp. 1-13, 2026.
DexTeleop-0: Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy
H. Liu, Y. Jiang, H. Park, Y. Xue, Z. Wang, "DexTeleop-0: Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy," arXiv preprint arXiv:2606.23431, 2026.
Skeleton-Aware Hand-Arm Retargeting for Contact-Rich Dexterous Teleoperation
K. Li, Y. Jiang, M. Zhao, Q. Wang, and H. Liu, "Skeleton-Aware Hand-Arm Retargeting for Contact-Rich Dexterous Teleoperation," in Proceedings of the 2026 International Conference on Embodied Intelligence and Robotics (EIR 2026), 2026, pp. 1-9.
Attention Distribution via Vision Language Models for Interactive Decision-Making and Motion Planning in Autonomous Driving
B. Ma, H. Liu, and J. Ma, "Attention Distribution via Vision Language Models for Interactive Decision-Making and Motion Planning in Autonomous Driving," in Proceedings of the 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026, pp. 1-8.
An Intention-Driven Lane Change Framework Considering Heterogeneous Dynamic Cooperation in Mixed-Traffic Environments
X. Qiu, H. Liu, Y. Pan, J. Ma, and X. Zheng, "An Intention-Driven Lane Change Framework Considering Heterogeneous Dynamic Cooperation in Mixed-Traffic Environments," IEEE Transactions on Intelligent Transportation Systems, vol. 0, no. 0, pp. 1-13, 2026.
RoCo Challenge at AAAI 2026: Benchmarking Robotic Collaborative Manipulation for Assembly Towards Industrial Automation
H. Liu, Y. Zhou, Z. Wu, Z. Ji, Z. Shan, Q. Wang, R. Liu, Z. Yang, Y. Gu, S. Khan, S. Yan, J. Liu, H. Zhu, C. Liu, J. Yang, J. Zhang, Z. Wang, "RoCo Challenge at AAAI 2026: Benchmarking Robotic Collaborative Manipulation for Assembly Towards Industrial Automation," arXiv preprint arXiv:2603.15469, 2026.
MoE-ACT: Scaling Multi-Task Bimanual Manipulation with Sparse Language-Conditioned Mixture-of-Experts Transformers
K. Guo, H. Liu, Y. Sun, R. Zhao, J. Zhou, J. Ma, "MoE-ACT: Scaling Multi-Task Bimanual Manipulation with Sparse Language-Conditioned Mixture-of-Experts Transformers," arXiv preprint arXiv:2603.15265, 2026.
UniManip: General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph
H. Liu, Y. Xue, Y. Zhou, H. Deng, Y. Liang, L. Xie, Z. Wang, "UniManip: General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph," arXiv preprint arXiv:2602.13086, 2026.
VLM-E2E: Enhancing End-to-End Autonomous Driving with Multimodal Driver Attention Fusion
P. Liu, H. Liu, H. Liu, X. Liu, J. Ni, and J. Ma, "VLM-E2E: Enhancing End-to-End Autonomous Driving with Multimodal Driver Attention Fusion," in Proceedings of the 2026 IEEE International Conference on Robotics and Automation (ICRA), 2026, pp. 1-8.
A Survey on Reinforcement Learning of Vision-Language-Action Models for Robotic Manipulation
H. Deng, Z. Wu, H. Liu, W. Guo, Y. Xue, Z. Shan, C. Zhang, B. Jia, Y. Ling, G. Lu, and Z. Wang, "A Survey on Reinforcement Learning of Vision-Language-Action Models for Robotic Manipulation," TechRxiv, 2025. doi: 10.36227/techrxiv.176531955.54563920/v1
An Autonomous Mobility on Demand Platform Supporting Cooperative Driving with Visual Context Generation for LMMs
H. Liu, H. Liu, and J. Ma, "An Autonomous Mobility on Demand Platform Supporting Cooperative Driving with Visual Context Generation for LMMs," in Proceedings of IEEE International Conference on Intelligent Transportation Systems (ITSC), IEEE, 2025, pp. 1-8.
Human-like Driving: A Comprehensive Survey from Depth and Breadth
H. Lu, J. Yang, Y. Liu, S. Shen, H. Liu, X. Zheng, and H. Yang, "Human-like driving: A comprehensive survey from depth and breadth," Artificial Intelligence for Transportation, vol. 3, p. 100033, 2025.
Diffeomorphism-Transformed Iterative Linear Quadratic Regulator for Constrained Motion Planning in Autonomous Driving
Z. Zhu, H. Liu, W. Wang, J. Duan, H. Zhao, and J. Ma, "Diffeomorphism-Transformed Iterative Linear Quadratic Regulator for Constrained Motion Planning in Autonomous Driving," IEEE Transactions on Intelligent Transportation Systems, vol. 0, no. 0, pp. 1-15, 2025.
VLM-UDMC: VLM-Enhanced Unified Decision-Making and Motion Control for Urban Autonomous Driving
H. Liu, H. Guo, P. Liu, B. Ma, Y. Zhang, J. Ma, and T. H. Lee, "VLM-UDMC: VLM-Enhanced Unified Decision-Making and Motion Control for Urban Autonomous Driving," arXiv preprint arXiv:2507.15266, 2025.
RoboDexVLM: Visual Language Model-Enabled Task Planning and Motion Control for Dexterous Robot Manipulation
H. Liu, S. Guo, P. Mai, J. Cao, H. Li, and J. Ma, "RoboDexVLM: Visual Language Model-Enabled Task Planning and Motion Control for Dexterous Robot Manipulation," in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025, pp. 1-8.
LMMCoDrive: Cooperative Driving with Large Multimodal Models
H. Liu, R. Yao, Z. Huang, S. Shen, and J. Ma, "LMMCoDrive: Cooperative Driving with Large Multimodal Model," in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025, pp. 1-8.
UDMC: Unified Decision-Making and Control Framework for Urban Autonomous Driving with Motion Prediction of Traffic Participants
H. Liu, K. Chen, Y. Li, Z. Huang, M. Liu, and J. Ma, "UDMC: Unified Decision-Making and Control Framework for Urban Autonomous Driving with Motion Prediction of Traffic Participants," IEEE Transactions on Intelligent Transportation Systems, , vol. 26, no. 5, pp. 5856-871, 2025.
Robot Navigation in Unknown and Cluttered Workspace with Dynamical System Modulation in Starshaped Roadmap
K. Chen, H. Liu, Y. Li, J. Duan, L. Zhu, and J. Ma, "Robot navigation in unknown and cluttered workspace with dynamical system modulation in starshaped roadmap," in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), IEEE, 2025, pp. 1-7.
CoDriveVLM: VLM-Enhanced Urban Cooperative Dispatching and Motion Planning for Future Autonomous Mobility on Demand Systems
H. Liu, R. Yao, W. Liu, Z. Huang, S. Shen, and J. Ma, "CoDriveVLM: VLM-enhanced urban cooperative dispatching and motion planning for future autonomous mobility on demand systems," arXiv preprint arXiv:2501.06132, 2025.
Synergizing Decision Making and Trajectory Planning Using Two-Stage Optimization for Autonomous Vehicles
W. Liu, H. Liu, L. Zheng, Z. Huang, and J. Ma, "Synergizing Decision Making and Trajectory Planning Using Two-Stage Optimization for Autonomous Vehicles," IEEE Transactions on Vehicular Technology, vol. 74, no. 4, pp. 5489-503, 2025.
Real-Time Teleoperation in Motion Mapping for Medical Robot Based on Robot Manipulator and Haptic Device
P. Peuchpen, H. Liu, and J. Ma, "Real-Time Teleoperation in Motion Mapping for Medical Robot Based on Robot Manipulator and Haptic Device," in Proceedings of IEEE International Conference on Robotics and Biomimetics (ROBIO), IEEE, 2024, pp. 1-6.
Enhance Planning with Physics-informed Safety Controller for End-to-end Autonomous Driving
H. Zhou, H. Liu, H. Lu, J. Ma, and Y. Ji, "Enhance planning with physics-informed safety controller for end-to-end autonomous driving," in Proceedings of IEEE International Conference on Robotics and Biomimetics (ROBIO), IEEE, 2024, pp. 1-8.
Parallel optimization with hard safety constraints for cooperative planning of connected autonomous vehicles
Z. Huang, H. Liu, S. Shen, and J. Ma, "Parallel optimization with hard safety constraints for cooperative planning of connected autonomous vehicles," in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), IEEE, 2024, pp. 1-7.
Improved consensus ADMM for cooperative motion planning of large-scale connected autonomous vehicles with limited communication
H. Liu, Z. Huang, Z. Zhu, Y. Li, S. Shen, and J. Ma, "Improved consensus ADMM for cooperative motion planning of large-scale connected autonomous vehicles with limited communication," IEEE Transactions on Intelligent Vehicles, vol. 9, no. 11, pp. 7222-238, 2024.
Incremental learning-based real-time trajectory prediction for autonomous driving via sparse Gaussian process regression
H. Liu, K. Chen, and J. Ma, "Incremental learning-based real-time trajectory prediction for autonomous driving via sparse Gaussian process regression," in Proceedings of Intelligent Vehicles Symposium(IV), IEEE, 2024, pp. 1-7.
Geometry-aware safety-critical local reactive controller for robot navigation in unknown and cluttered environments
Y. Li, X. Tang, K. Chen, C. Zheng, H. Liu, and J. Ma, "Geometry-aware safety-critical local reactive controller for robot navigation in unknown and cluttered environments," IEEE Robotics and Automation Letters, vol. 9, no. 4, pp. 3419 - 3426, 2024.
Integrated behavior planning and motion control for autonomous vehicles with traffic rules compliance
H. Liu, K. Chen, Y. Li, Z. Huang, J. Duan, and J. Ma, "Integrated behavior planning and motion control for autonomous vehicles with traffic rules compliance," in Proceedings of IEEE International Conference on Robotics and Biomimetics (ROBIO), IEEE, 2023, pp. 1-7.
Real-time parallel trajectory optimization with spatiotemporal safety constraints for autonomous driving in congested traffic
L. Zheng, R. Yang, Z. Peng, H. Liu, M. Y. Wang, and J. Ma, "Real-time parallel trajectory optimization with spatiotemporal safety constraints for autonomous driving in congested traffic," in Proceedings of 2023 IEEE 26th International Conference on Intelligent Transportation Systems (ITSC), IEEE, 2023, pp. 1186-1193.
Bio-inspired robot swarm path formation with local sensor scope
Y. Zhao, Z. Qu, H. Liu, and R. Zhu, “Bio-inspired robot swarm path formation with local sensor scope, Applied Intelligence, vol. 53, no. 1, pp. 17310-17326, 2022.
Solving a Multi-robot Search Problem with Bionic Sarsa Algorithm and Artificial Potential Field
H. Liu, Z. Qu and R. Zhu, "Solving a Multi-robot Search Problem with Bionic Sarsa Algorithm and Artificial Potential Field," 2021 China Automation Congress (CAC), Beijing, China, 2021, pp. 1830-1835.
Research on Robot Visual Grabbing Based on Mechanism Analysis
H. Liu, Z. Liu, H. Liu and W. Lin, "Research on Robot Visual Grabbing Based on Mechanism Analysis," 2021 IEEE 11th Annual International Conference on CYBER Technology in Automation, Control, and Intelligent Systems (CYBER), Jiaxing, China, 2021, pp. 181-186.
Robotic manipulation
UniIntervene: Agentic Intervention for Efficient Real-World Reinforcement Learning
H. Deng, Y. Gao, Y. Lin, H. Liu, Z. Wu, Z. Wang, "UniIntervene: Agentic Intervention for Efficient Real-World Reinforcement Learning," Proceedings of the Conference on Robot Learning (CoRL), 2026.
RATE: Risk-Aware Tactile Encoding for Contact-rich Robotic Manipulation
Y. Jiang, H. Liu, J. Zheng, Z. Ding, W. Yuan, Z. Wang, "RATE: Risk-Aware Tactile Encoding for Contact-rich Robotic Manipulation," arXiv preprint arXiv:2610.03538, 2026.
Facet-0: A Robotic Foundation Model for Contact-Rich Precise Manipulation
H. Deng, H. Liu, W. Guo, Y. Ling, Z. Yang, Y. Xue, H. Sun, L. Wang, Z. Wang, "Facet-0: A Robotic Foundation Model for Contact-Rich Precise Manipulation," arXiv preprint arXiv:2609.01596, 2026.
DexTeleop-0: Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy
H. Liu, Y. Jiang, H. Park, Y. Xue, Z. Wang, "DexTeleop-0: Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy," arXiv preprint arXiv:2606.23431, 2026.
Skeleton-Aware Hand-Arm Retargeting for Contact-Rich Dexterous Teleoperation
K. Li, Y. Jiang, M. Zhao, Q. Wang, and H. Liu, "Skeleton-Aware Hand-Arm Retargeting for Contact-Rich Dexterous Teleoperation," in Proceedings of the 2026 International Conference on Embodied Intelligence and Robotics (EIR 2026), 2026, pp. 1-9.
RoCo Challenge at AAAI 2026: Benchmarking Robotic Collaborative Manipulation for Assembly Towards Industrial Automation
H. Liu, Y. Zhou, Z. Wu, Z. Ji, Z. Shan, Q. Wang, R. Liu, Z. Yang, Y. Gu, S. Khan, S. Yan, J. Liu, H. Zhu, C. Liu, J. Yang, J. Zhang, Z. Wang, "RoCo Challenge at AAAI 2026: Benchmarking Robotic Collaborative Manipulation for Assembly Towards Industrial Automation," arXiv preprint arXiv:2603.15469, 2026.
MoE-ACT: Scaling Multi-Task Bimanual Manipulation with Sparse Language-Conditioned Mixture-of-Experts Transformers
K. Guo, H. Liu, Y. Sun, R. Zhao, J. Zhou, J. Ma, "MoE-ACT: Scaling Multi-Task Bimanual Manipulation with Sparse Language-Conditioned Mixture-of-Experts Transformers," arXiv preprint arXiv:2603.15265, 2026.
UniManip: General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph
H. Liu, Y. Xue, Y. Zhou, H. Deng, Y. Liang, L. Xie, Z. Wang, "UniManip: General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph," arXiv preprint arXiv:2602.13086, 2026.
A Survey on Reinforcement Learning of Vision-Language-Action Models for Robotic Manipulation
H. Deng, Z. Wu, H. Liu, W. Guo, Y. Xue, Z. Shan, C. Zhang, B. Jia, Y. Ling, G. Lu, and Z. Wang, "A Survey on Reinforcement Learning of Vision-Language-Action Models for Robotic Manipulation," TechRxiv, 2025. doi: 10.36227/techrxiv.176531955.54563920/v1
RoboDexVLM: Visual Language Model-Enabled Task Planning and Motion Control for Dexterous Robot Manipulation
H. Liu, S. Guo, P. Mai, J. Cao, H. Li, and J. Ma, "RoboDexVLM: Visual Language Model-Enabled Task Planning and Motion Control for Dexterous Robot Manipulation," in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025, pp. 1-8.
Real-Time Teleoperation in Motion Mapping for Medical Robot Based on Robot Manipulator and Haptic Device
P. Peuchpen, H. Liu, and J. Ma, "Real-Time Teleoperation in Motion Mapping for Medical Robot Based on Robot Manipulator and Haptic Device," in Proceedings of IEEE International Conference on Robotics and Biomimetics (ROBIO), IEEE, 2024, pp. 1-6.
Research on Robot Visual Grabbing Based on Mechanism Analysis
H. Liu, Z. Liu, H. Liu and W. Lin, "Research on Robot Visual Grabbing Based on Mechanism Analysis," 2021 IEEE 11th Annual International Conference on CYBER Technology in Automation, Control, and Intelligent Systems (CYBER), Jiaxing, China, 2021, pp. 181-186.
Robot navigation
Robot Navigation in Unknown and Cluttered Workspace with Dynamical System Modulation in Starshaped Roadmap
K. Chen, H. Liu, Y. Li, J. Duan, L. Zhu, and J. Ma, "Robot navigation in unknown and cluttered workspace with dynamical system modulation in starshaped roadmap," in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), IEEE, 2025, pp. 1-7.
Geometry-aware safety-critical local reactive controller for robot navigation in unknown and cluttered environments
Y. Li, X. Tang, K. Chen, C. Zheng, H. Liu, and J. Ma, "Geometry-aware safety-critical local reactive controller for robot navigation in unknown and cluttered environments," IEEE Robotics and Automation Letters, vol. 9, no. 4, pp. 3419 - 3426, 2024.
Bio-inspired robot swarm path formation with local sensor scope
Y. Zhao, Z. Qu, H. Liu, and R. Zhu, “Bio-inspired robot swarm path formation with local sensor scope, Applied Intelligence, vol. 53, no. 1, pp. 17310-17326, 2022.
Solving a Multi-robot Search Problem with Bionic Sarsa Algorithm and Artificial Potential Field
H. Liu, Z. Qu and R. Zhu, "Solving a Multi-robot Search Problem with Bionic Sarsa Algorithm and Artificial Potential Field," 2021 China Automation Congress (CAC), Beijing, China, 2021, pp. 1830-1835.
Motion planning and control
Facet-0: A Robotic Foundation Model for Contact-Rich Precise Manipulation
H. Deng, H. Liu, W. Guo, Y. Ling, Z. Yang, Y. Xue, H. Sun, L. Wang, Z. Wang, "Facet-0: A Robotic Foundation Model for Contact-Rich Precise Manipulation," arXiv preprint arXiv:2609.01596, 2026.
DexTeleop-0: Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy
H. Liu, Y. Jiang, H. Park, Y. Xue, Z. Wang, "DexTeleop-0: Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy," arXiv preprint arXiv:2606.23431, 2026.
An Intention-Driven Lane Change Framework Considering Heterogeneous Dynamic Cooperation in Mixed-Traffic Environments
X. Qiu, H. Liu, Y. Pan, J. Ma, and X. Zheng, "An Intention-Driven Lane Change Framework Considering Heterogeneous Dynamic Cooperation in Mixed-Traffic Environments," IEEE Transactions on Intelligent Transportation Systems, vol. 0, no. 0, pp. 1-13, 2026.
RoCo Challenge at AAAI 2026: Benchmarking Robotic Collaborative Manipulation for Assembly Towards Industrial Automation
H. Liu, Y. Zhou, Z. Wu, Z. Ji, Z. Shan, Q. Wang, R. Liu, Z. Yang, Y. Gu, S. Khan, S. Yan, J. Liu, H. Zhu, C. Liu, J. Yang, J. Zhang, Z. Wang, "RoCo Challenge at AAAI 2026: Benchmarking Robotic Collaborative Manipulation for Assembly Towards Industrial Automation," arXiv preprint arXiv:2603.15469, 2026.
MoE-ACT: Scaling Multi-Task Bimanual Manipulation with Sparse Language-Conditioned Mixture-of-Experts Transformers
K. Guo, H. Liu, Y. Sun, R. Zhao, J. Zhou, J. Ma, "MoE-ACT: Scaling Multi-Task Bimanual Manipulation with Sparse Language-Conditioned Mixture-of-Experts Transformers," arXiv preprint arXiv:2603.15265, 2026.
UniManip: General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph
H. Liu, Y. Xue, Y. Zhou, H. Deng, Y. Liang, L. Xie, Z. Wang, "UniManip: General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph," arXiv preprint arXiv:2602.13086, 2026.
An Autonomous Mobility on Demand Platform Supporting Cooperative Driving with Visual Context Generation for LMMs
H. Liu, H. Liu, and J. Ma, "An Autonomous Mobility on Demand Platform Supporting Cooperative Driving with Visual Context Generation for LMMs," in Proceedings of IEEE International Conference on Intelligent Transportation Systems (ITSC), IEEE, 2025, pp. 1-8.
Diffeomorphism-Transformed Iterative Linear Quadratic Regulator for Constrained Motion Planning in Autonomous Driving
Z. Zhu, H. Liu, W. Wang, J. Duan, H. Zhao, and J. Ma, "Diffeomorphism-Transformed Iterative Linear Quadratic Regulator for Constrained Motion Planning in Autonomous Driving," IEEE Transactions on Intelligent Transportation Systems, vol. 0, no. 0, pp. 1-15, 2025.
VLM-UDMC: VLM-Enhanced Unified Decision-Making and Motion Control for Urban Autonomous Driving
H. Liu, H. Guo, P. Liu, B. Ma, Y. Zhang, J. Ma, and T. H. Lee, "VLM-UDMC: VLM-Enhanced Unified Decision-Making and Motion Control for Urban Autonomous Driving," arXiv preprint arXiv:2507.15266, 2025.
RoboDexVLM: Visual Language Model-Enabled Task Planning and Motion Control for Dexterous Robot Manipulation
H. Liu, S. Guo, P. Mai, J. Cao, H. Li, and J. Ma, "RoboDexVLM: Visual Language Model-Enabled Task Planning and Motion Control for Dexterous Robot Manipulation," in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025, pp. 1-8.
LMMCoDrive: Cooperative Driving with Large Multimodal Models
H. Liu, R. Yao, Z. Huang, S. Shen, and J. Ma, "LMMCoDrive: Cooperative Driving with Large Multimodal Model," in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025, pp. 1-8.
UDMC: Unified Decision-Making and Control Framework for Urban Autonomous Driving with Motion Prediction of Traffic Participants
H. Liu, K. Chen, Y. Li, Z. Huang, M. Liu, and J. Ma, "UDMC: Unified Decision-Making and Control Framework for Urban Autonomous Driving with Motion Prediction of Traffic Participants," IEEE Transactions on Intelligent Transportation Systems, , vol. 26, no. 5, pp. 5856-871, 2025.
Robot Navigation in Unknown and Cluttered Workspace with Dynamical System Modulation in Starshaped Roadmap
K. Chen, H. Liu, Y. Li, J. Duan, L. Zhu, and J. Ma, "Robot navigation in unknown and cluttered workspace with dynamical system modulation in starshaped roadmap," in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), IEEE, 2025, pp. 1-7.
CoDriveVLM: VLM-Enhanced Urban Cooperative Dispatching and Motion Planning for Future Autonomous Mobility on Demand Systems
H. Liu, R. Yao, W. Liu, Z. Huang, S. Shen, and J. Ma, "CoDriveVLM: VLM-enhanced urban cooperative dispatching and motion planning for future autonomous mobility on demand systems," arXiv preprint arXiv:2501.06132, 2025.
Synergizing Decision Making and Trajectory Planning Using Two-Stage Optimization for Autonomous Vehicles
W. Liu, H. Liu, L. Zheng, Z. Huang, and J. Ma, "Synergizing Decision Making and Trajectory Planning Using Two-Stage Optimization for Autonomous Vehicles," IEEE Transactions on Vehicular Technology, vol. 74, no. 4, pp. 5489-503, 2025.
Enhance Planning with Physics-informed Safety Controller for End-to-end Autonomous Driving
H. Zhou, H. Liu, H. Lu, J. Ma, and Y. Ji, "Enhance planning with physics-informed safety controller for end-to-end autonomous driving," in Proceedings of IEEE International Conference on Robotics and Biomimetics (ROBIO), IEEE, 2024, pp. 1-8.
Parallel optimization with hard safety constraints for cooperative planning of connected autonomous vehicles
Z. Huang, H. Liu, S. Shen, and J. Ma, "Parallel optimization with hard safety constraints for cooperative planning of connected autonomous vehicles," in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), IEEE, 2024, pp. 1-7.
Improved consensus ADMM for cooperative motion planning of large-scale connected autonomous vehicles with limited communication
H. Liu, Z. Huang, Z. Zhu, Y. Li, S. Shen, and J. Ma, "Improved consensus ADMM for cooperative motion planning of large-scale connected autonomous vehicles with limited communication," IEEE Transactions on Intelligent Vehicles, vol. 9, no. 11, pp. 7222-238, 2024.
Geometry-aware safety-critical local reactive controller for robot navigation in unknown and cluttered environments
Y. Li, X. Tang, K. Chen, C. Zheng, H. Liu, and J. Ma, "Geometry-aware safety-critical local reactive controller for robot navigation in unknown and cluttered environments," IEEE Robotics and Automation Letters, vol. 9, no. 4, pp. 3419 - 3426, 2024.
Integrated behavior planning and motion control for autonomous vehicles with traffic rules compliance
H. Liu, K. Chen, Y. Li, Z. Huang, J. Duan, and J. Ma, "Integrated behavior planning and motion control for autonomous vehicles with traffic rules compliance," in Proceedings of IEEE International Conference on Robotics and Biomimetics (ROBIO), IEEE, 2023, pp. 1-7.
Autonomous driving
Effects of Environmental Perception and Planned Maneuver Visualization on Takeover Performance in Silent Failure Scenarios
S. Yan, H. Liu, J. Zhang, J. Wang, J. Ma and D. He, "Effects of Environmental Perception and Planned Maneuver Visualization on Takeover Performance in Silent Failure Scenarios," International Journal of Human - Computer Studies, vol. 0, no. 0, pp. 1-34, 2026.
Potential-Game Structured Cooperative Eco-Driving for Mixed Platoons at Signalized Intersections
J. Fan, H. Liu, Y. Zou, W. Liu, and J. Ma, "Potential-Game Structured Cooperative Eco-Driving for Mixed Platoons at Signalized Intersections," Unmanned Systems, vol. 0, no. 0, pp. 1-18, 2026.
Behavioral Uncertainty-Aware Attention Allocation via VLMs for Interactive Autonomous Driving
B. Ma, H. Liu, R. Zhong, P. Liu, X. Zhou, and J. Ma, "Behavioral Uncertainty-Aware Attention Allocation via VLMs for Interactive Autonomous Driving," IEEE Transactions on Vehicular Technology, vol. 0, no. 0, pp. 1-13, 2026.
Attention Distribution via Vision Language Models for Interactive Decision-Making and Motion Planning in Autonomous Driving
B. Ma, H. Liu, and J. Ma, "Attention Distribution via Vision Language Models for Interactive Decision-Making and Motion Planning in Autonomous Driving," in Proceedings of the 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026, pp. 1-8.
An Intention-Driven Lane Change Framework Considering Heterogeneous Dynamic Cooperation in Mixed-Traffic Environments
X. Qiu, H. Liu, Y. Pan, J. Ma, and X. Zheng, "An Intention-Driven Lane Change Framework Considering Heterogeneous Dynamic Cooperation in Mixed-Traffic Environments," IEEE Transactions on Intelligent Transportation Systems, vol. 0, no. 0, pp. 1-13, 2026.
VLM-E2E: Enhancing End-to-End Autonomous Driving with Multimodal Driver Attention Fusion
P. Liu, H. Liu, H. Liu, X. Liu, J. Ni, and J. Ma, "VLM-E2E: Enhancing End-to-End Autonomous Driving with Multimodal Driver Attention Fusion," in Proceedings of the 2026 IEEE International Conference on Robotics and Automation (ICRA), 2026, pp. 1-8.
An Autonomous Mobility on Demand Platform Supporting Cooperative Driving with Visual Context Generation for LMMs
H. Liu, H. Liu, and J. Ma, "An Autonomous Mobility on Demand Platform Supporting Cooperative Driving with Visual Context Generation for LMMs," in Proceedings of IEEE International Conference on Intelligent Transportation Systems (ITSC), IEEE, 2025, pp. 1-8.
Human-like Driving: A Comprehensive Survey from Depth and Breadth
H. Lu, J. Yang, Y. Liu, S. Shen, H. Liu, X. Zheng, and H. Yang, "Human-like driving: A comprehensive survey from depth and breadth," Artificial Intelligence for Transportation, vol. 3, p. 100033, 2025.
Diffeomorphism-Transformed Iterative Linear Quadratic Regulator for Constrained Motion Planning in Autonomous Driving
Z. Zhu, H. Liu, W. Wang, J. Duan, H. Zhao, and J. Ma, "Diffeomorphism-Transformed Iterative Linear Quadratic Regulator for Constrained Motion Planning in Autonomous Driving," IEEE Transactions on Intelligent Transportation Systems, vol. 0, no. 0, pp. 1-15, 2025.
VLM-UDMC: VLM-Enhanced Unified Decision-Making and Motion Control for Urban Autonomous Driving
H. Liu, H. Guo, P. Liu, B. Ma, Y. Zhang, J. Ma, and T. H. Lee, "VLM-UDMC: VLM-Enhanced Unified Decision-Making and Motion Control for Urban Autonomous Driving," arXiv preprint arXiv:2507.15266, 2025.
LMMCoDrive: Cooperative Driving with Large Multimodal Models
H. Liu, R. Yao, Z. Huang, S. Shen, and J. Ma, "LMMCoDrive: Cooperative Driving with Large Multimodal Model," in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025, pp. 1-8.
UDMC: Unified Decision-Making and Control Framework for Urban Autonomous Driving with Motion Prediction of Traffic Participants
H. Liu, K. Chen, Y. Li, Z. Huang, M. Liu, and J. Ma, "UDMC: Unified Decision-Making and Control Framework for Urban Autonomous Driving with Motion Prediction of Traffic Participants," IEEE Transactions on Intelligent Transportation Systems, , vol. 26, no. 5, pp. 5856-871, 2025.
CoDriveVLM: VLM-Enhanced Urban Cooperative Dispatching and Motion Planning for Future Autonomous Mobility on Demand Systems
H. Liu, R. Yao, W. Liu, Z. Huang, S. Shen, and J. Ma, "CoDriveVLM: VLM-enhanced urban cooperative dispatching and motion planning for future autonomous mobility on demand systems," arXiv preprint arXiv:2501.06132, 2025.
Synergizing Decision Making and Trajectory Planning Using Two-Stage Optimization for Autonomous Vehicles
W. Liu, H. Liu, L. Zheng, Z. Huang, and J. Ma, "Synergizing Decision Making and Trajectory Planning Using Two-Stage Optimization for Autonomous Vehicles," IEEE Transactions on Vehicular Technology, vol. 74, no. 4, pp. 5489-503, 2025.
Enhance Planning with Physics-informed Safety Controller for End-to-end Autonomous Driving
H. Zhou, H. Liu, H. Lu, J. Ma, and Y. Ji, "Enhance planning with physics-informed safety controller for end-to-end autonomous driving," in Proceedings of IEEE International Conference on Robotics and Biomimetics (ROBIO), IEEE, 2024, pp. 1-8.
Parallel optimization with hard safety constraints for cooperative planning of connected autonomous vehicles
Z. Huang, H. Liu, S. Shen, and J. Ma, "Parallel optimization with hard safety constraints for cooperative planning of connected autonomous vehicles," in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), IEEE, 2024, pp. 1-7.
Improved consensus ADMM for cooperative motion planning of large-scale connected autonomous vehicles with limited communication
H. Liu, Z. Huang, Z. Zhu, Y. Li, S. Shen, and J. Ma, "Improved consensus ADMM for cooperative motion planning of large-scale connected autonomous vehicles with limited communication," IEEE Transactions on Intelligent Vehicles, vol. 9, no. 11, pp. 7222-238, 2024.
Incremental learning-based real-time trajectory prediction for autonomous driving via sparse Gaussian process regression
H. Liu, K. Chen, and J. Ma, "Incremental learning-based real-time trajectory prediction for autonomous driving via sparse Gaussian process regression," in Proceedings of Intelligent Vehicles Symposium(IV), IEEE, 2024, pp. 1-7.
Integrated behavior planning and motion control for autonomous vehicles with traffic rules compliance
H. Liu, K. Chen, Y. Li, Z. Huang, J. Duan, and J. Ma, "Integrated behavior planning and motion control for autonomous vehicles with traffic rules compliance," in Proceedings of IEEE International Conference on Robotics and Biomimetics (ROBIO), IEEE, 2023, pp. 1-7.
Real-time parallel trajectory optimization with spatiotemporal safety constraints for autonomous driving in congested traffic
L. Zheng, R. Yang, Z. Peng, H. Liu, M. Y. Wang, and J. Ma, "Real-time parallel trajectory optimization with spatiotemporal safety constraints for autonomous driving in congested traffic," in Proceedings of 2023 IEEE 26th International Conference on Intelligent Transportation Systems (ITSC), IEEE, 2023, pp. 1186-1193.
Human-robot interaction
Effects of Environmental Perception and Planned Maneuver Visualization on Takeover Performance in Silent Failure Scenarios
S. Yan, H. Liu, J. Zhang, J. Wang, J. Ma and D. He, "Effects of Environmental Perception and Planned Maneuver Visualization on Takeover Performance in Silent Failure Scenarios," International Journal of Human - Computer Studies, vol. 0, no. 0, pp. 1-34, 2026.
Humanoid locomotion
Tac4Loco: Learning Spatiotemporal Plantar Pressure Representations for Humanoid Locomotion
Z. Liu, S. Guo, Z. Li, J. Cao, H. Liu, P. Qu, Y. Zhang, J. Zhou, J. Ma, "Tac4Loco: Learning Spatiotemporal Plantar Pressure Representations for Humanoid Locomotion," arXiv preprint arXiv:2608.15766, 2026.
Survey
A Survey on Reinforcement Learning of Vision-Language-Action Models for Robotic Manipulation
H. Deng, Z. Wu, H. Liu, W. Guo, Y. Xue, Z. Shan, C. Zhang, B. Jia, Y. Ling, G. Lu, and Z. Wang, "A Survey on Reinforcement Learning of Vision-Language-Action Models for Robotic Manipulation," TechRxiv, 2025. doi: 10.36227/techrxiv.176531955.54563920/v1
Internship
- Part-time Research Assistant for a multimodal media research project, Department of Marketing, The Hong Kong University of Science and Technology
- Industrial Robot R&D, Siasun Robot&Automation Co., Ltd from Shenyang Institute of Automation, Chinese Academy of Sciences
Selected Honors
- Judge Appreciation Certificate, Ministry of Education of Singapore
- Outstanding Volunteer Award, CyberC, IEEE
- Winning Team (1st place) of the Venture Capital on Campus, HKSTP
- HKUST Postgraduate Scholarship (Guangzhou Pilot Scheme), Hong Kong University of Science and Technology
- Outstanding Graduate, Harbin Institute of Technology
- Chiang Chen Oversea Research Scholarship, Chiang Chen Industrial Charity Foundation
- He Gao Scholarship, Robotics Institute, Harbin Institute of Technology
- Chiang Chen Scholarship, School of Mechatronics Engineering, Harbin Institute of Technology
- Outstanding League Cadre, Harbin Institute of Technology
- First-class Scholarship for PG, Harbin Institute of Technology
- Outstanding UG Graduation Thesis, Faculty of Robot Science and Engineering, NEU
- Outstanding Graduate (Cadre), Northeastern University
- First-class Scholarship for UG, Northeastern University
- National Inspirational Scholarship, Ministry of Education of P.R. China
- Outstanding Student, Northeastern University
- Michelin Scholarship, Northeastern University
- Second Prize of the China University Mathematical Contest in Modeling (CUMCM), China Society for Industrial and Applied Mathematics