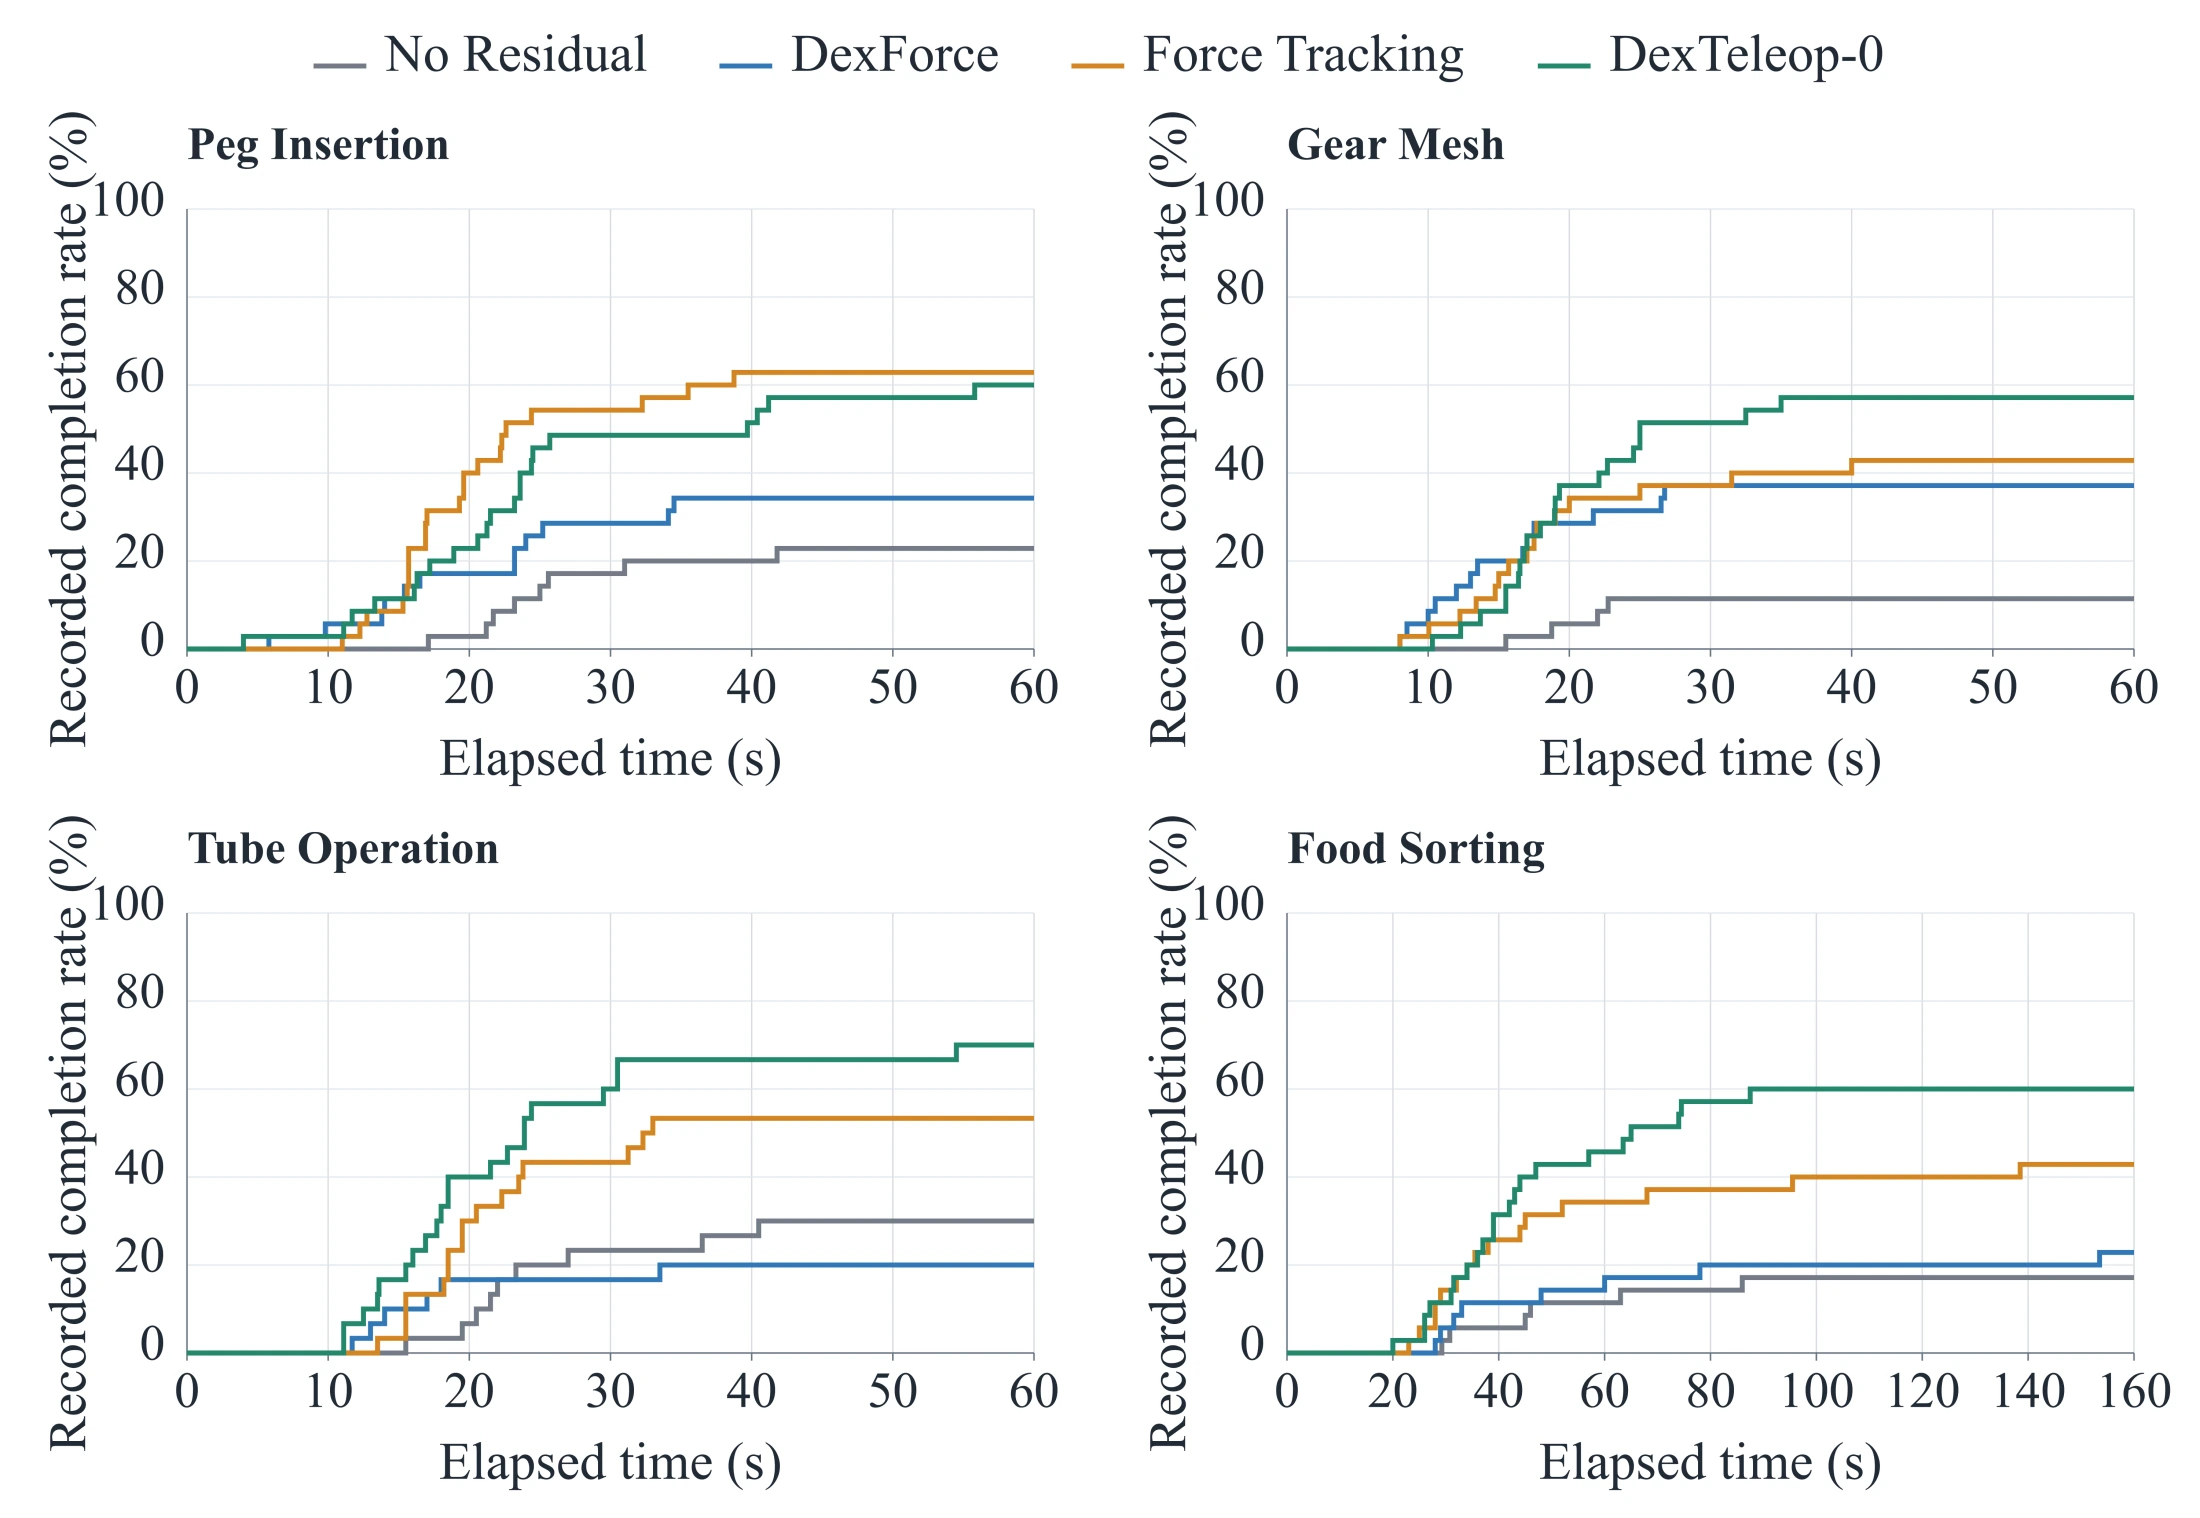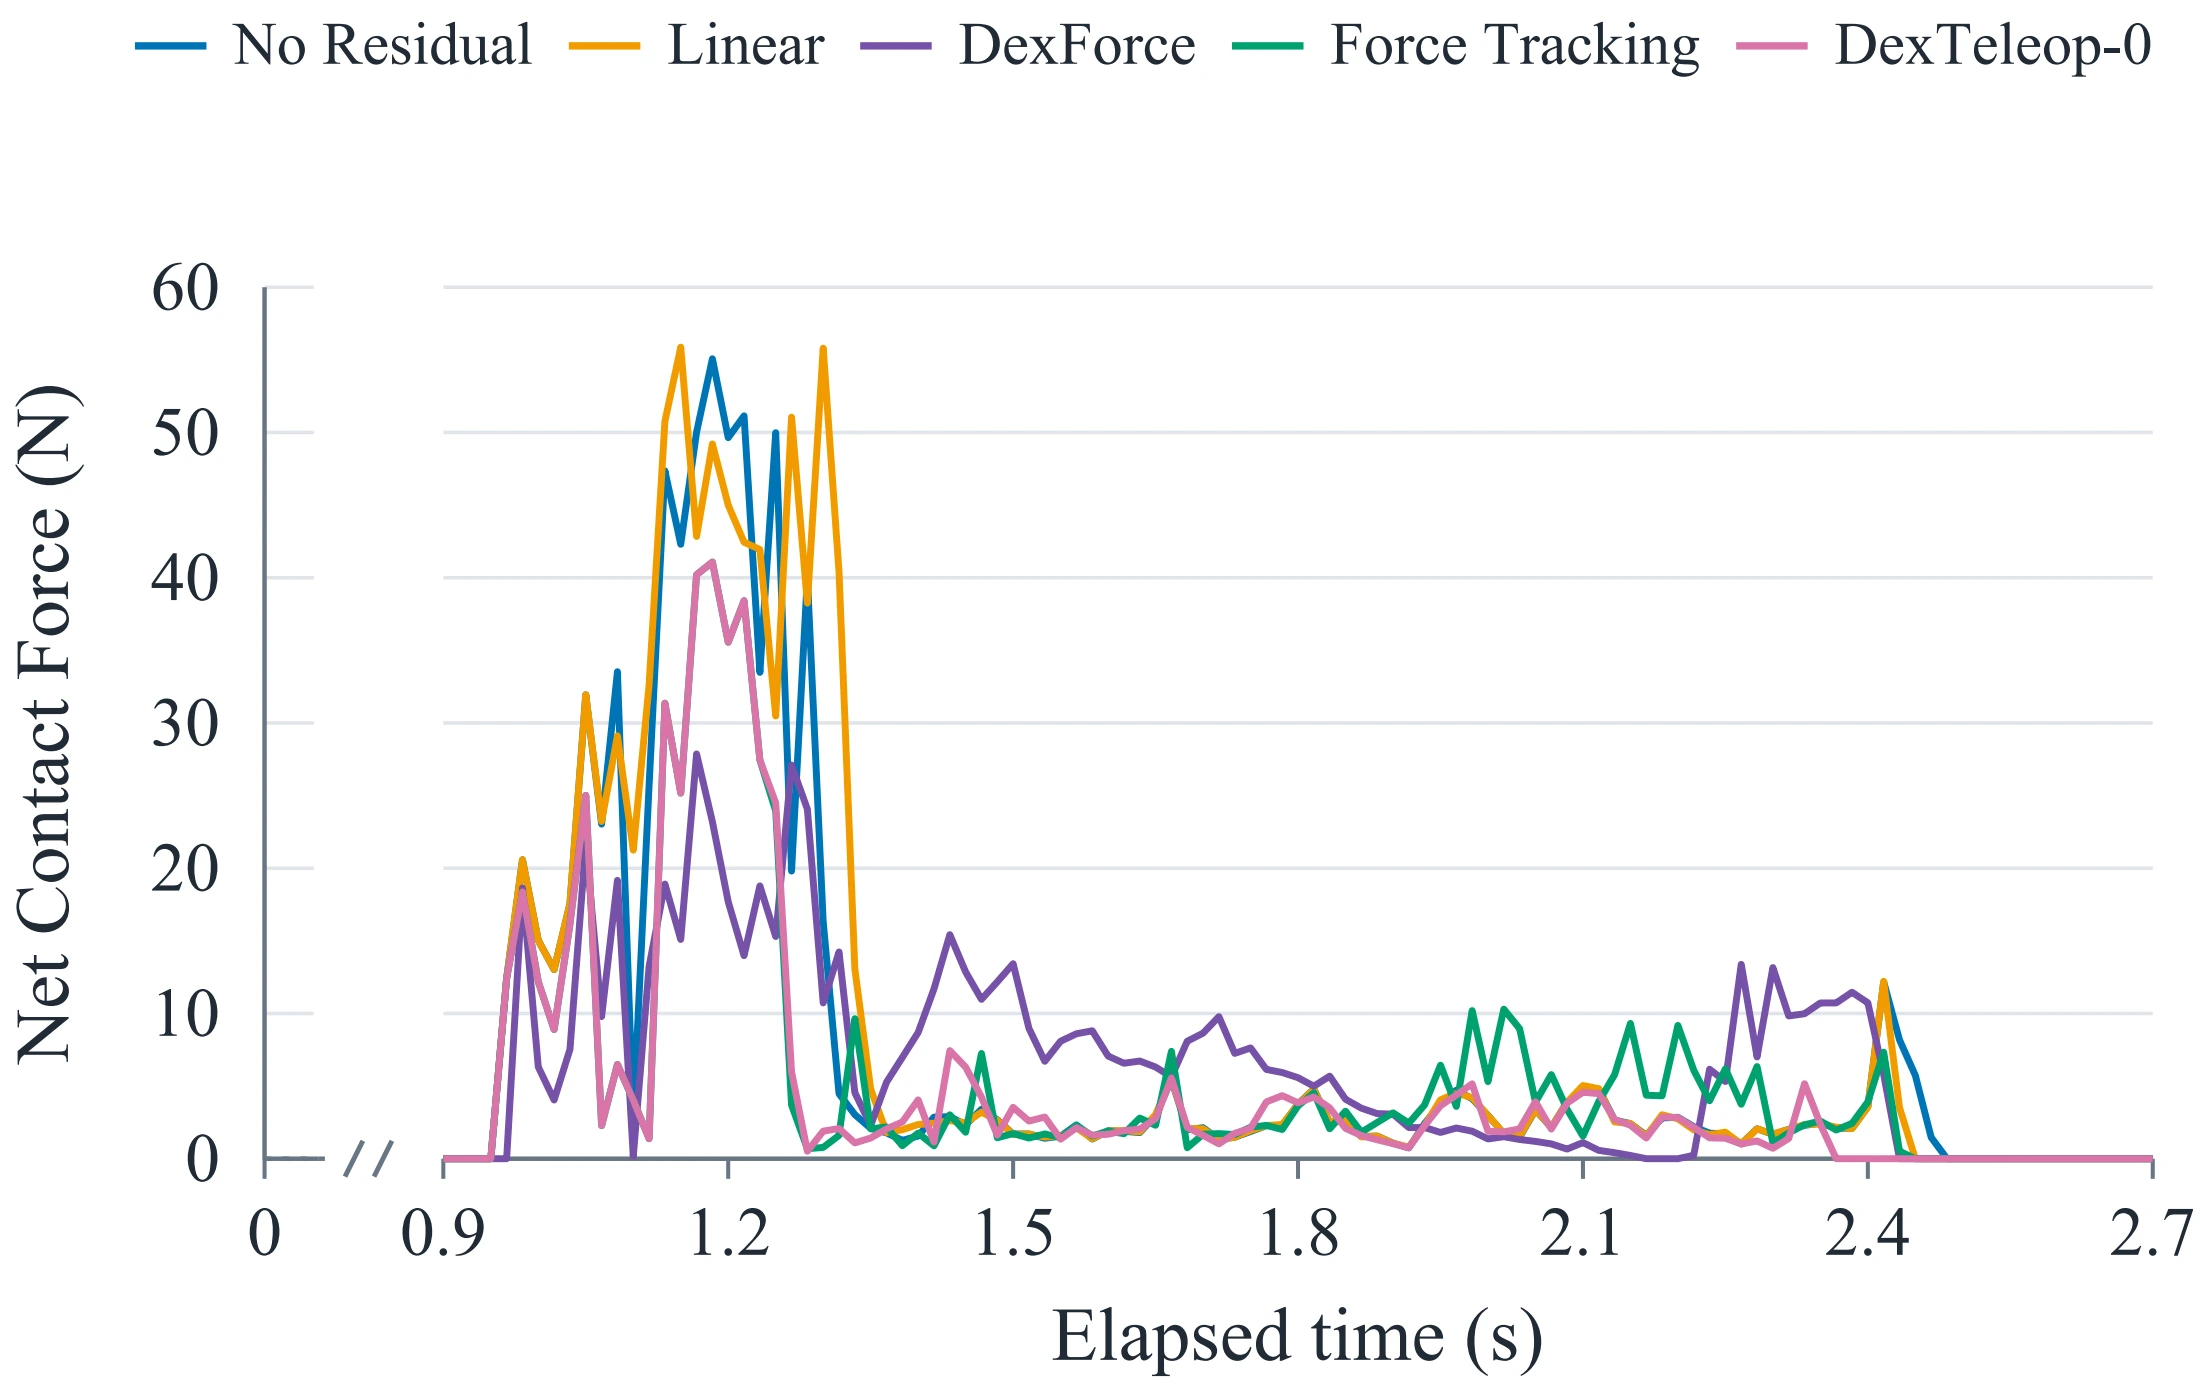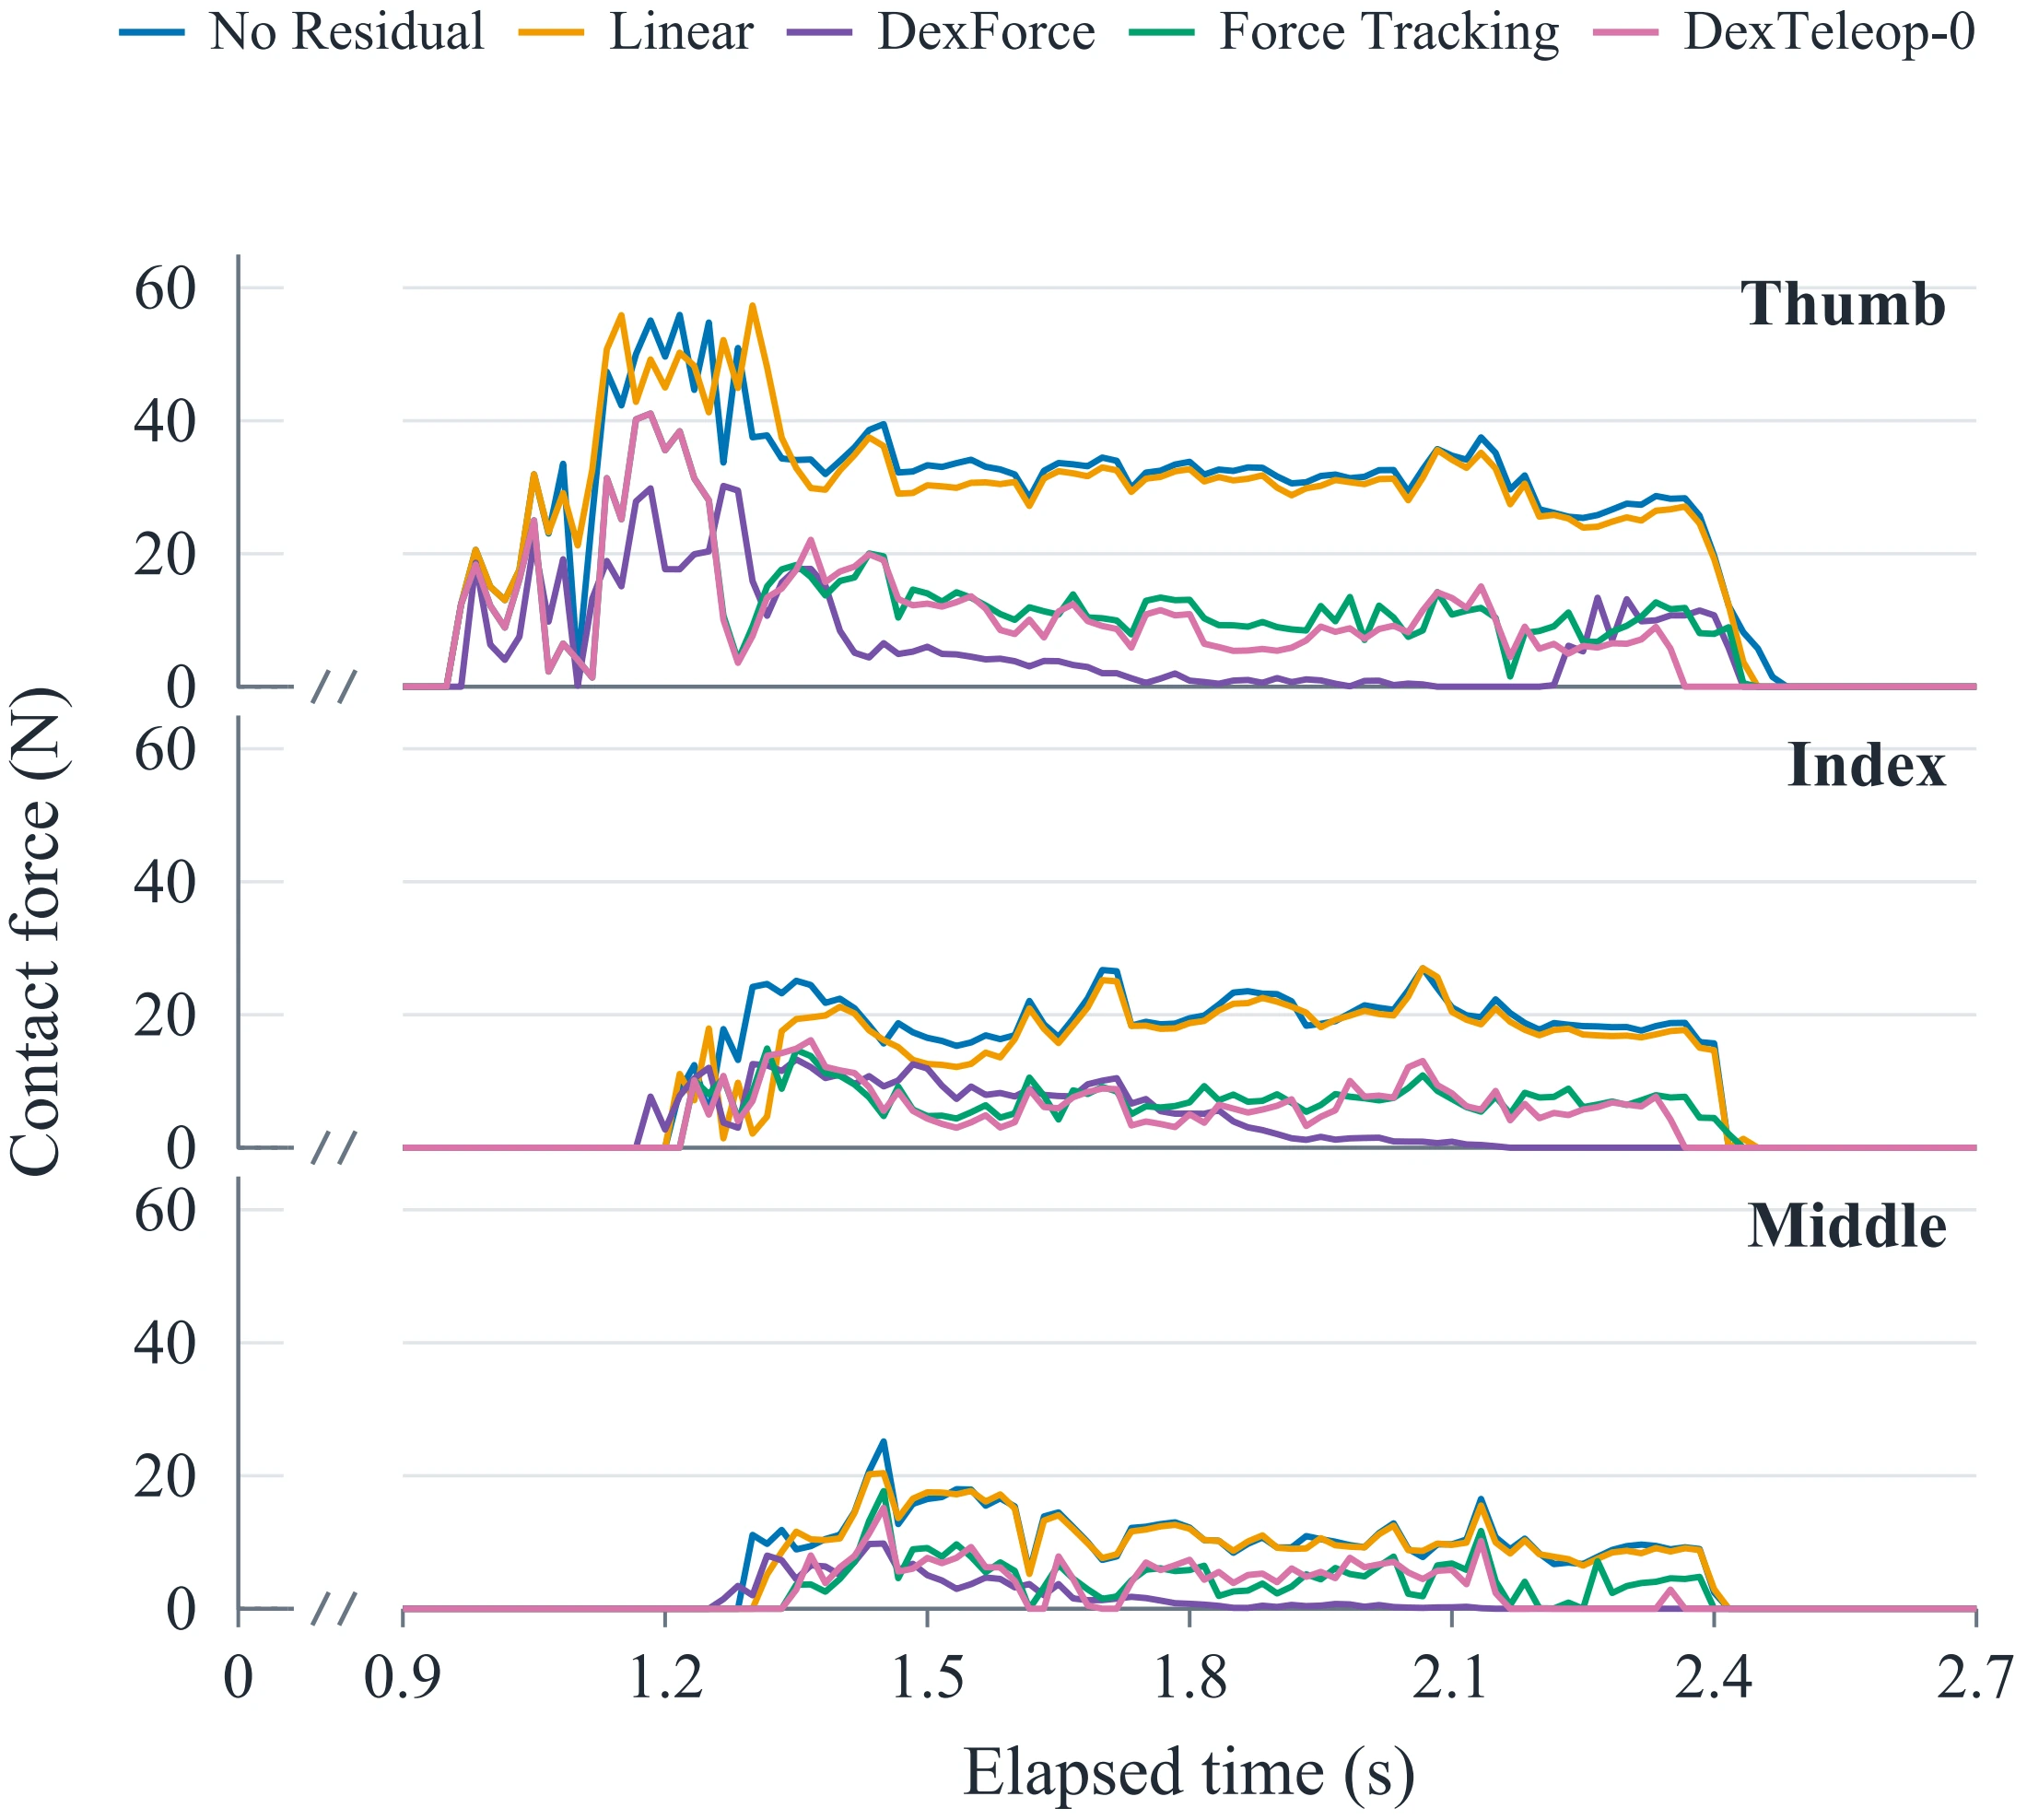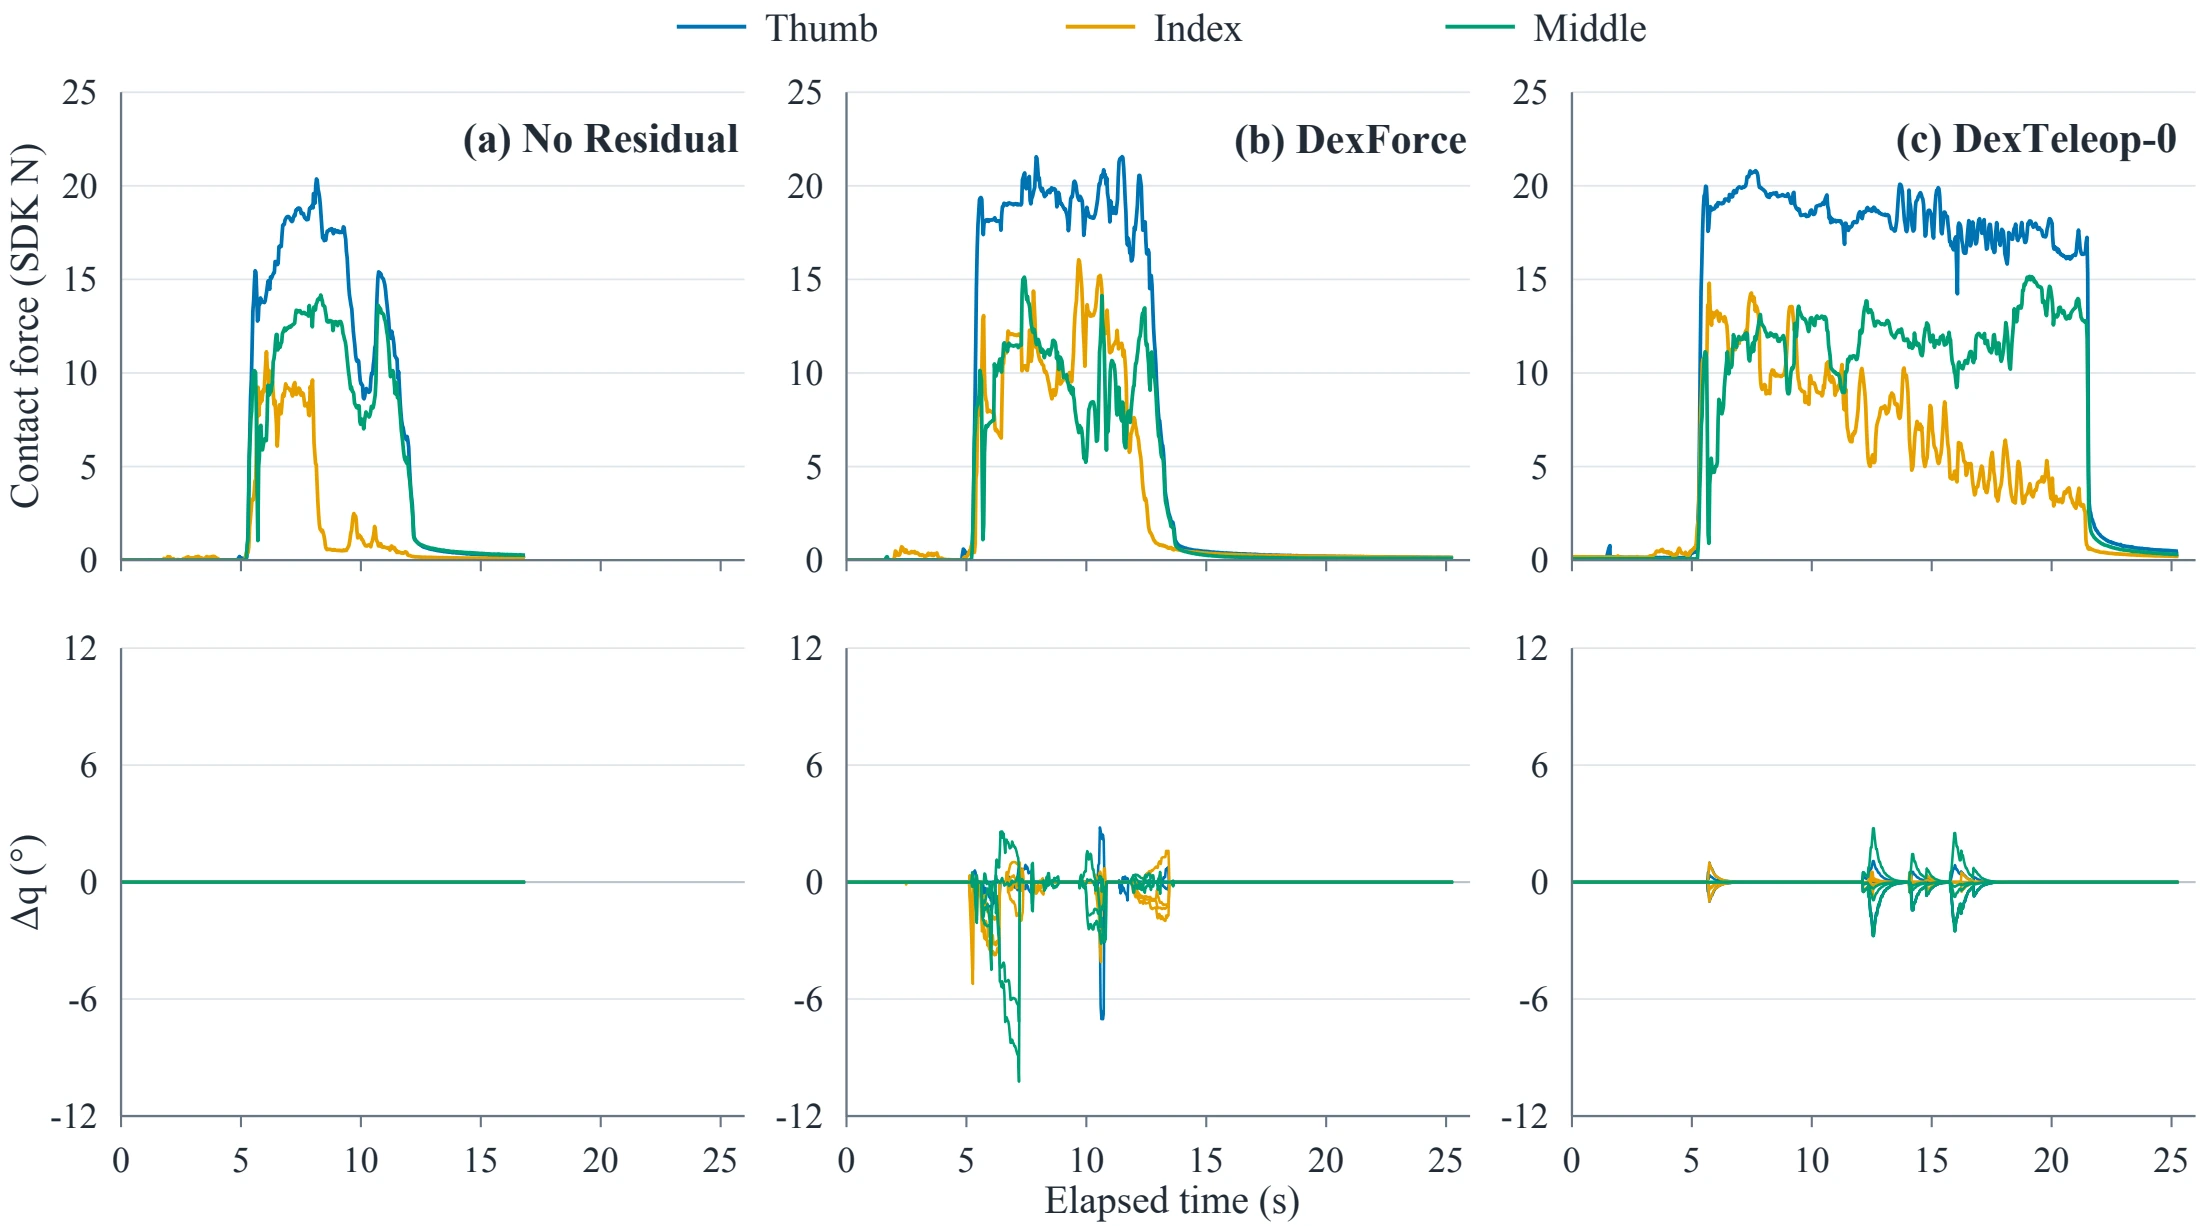
Separate contact tracking from moment regularization.
No Residual follows retargeted positions. Linear adjusts fingers independently. Force Tracking retains the full controller’s force objective, residual regularization, and bounds, with the moment weight set to zero.
| Method | Ball Assembly · final stage | Stir in Cup · final stage |
|---|---|---|
| No Residual | 11% | 49% |
| Linear | 1% | 44% |
| DexForce | 38% | 3% |
| Force Tracking | 88% | 49% |
| DexTeleop-0 | 91% | 62% |
Moment-term ablation. DexTeleop-0 reaches 91% versus 88% for Force Tracking on Ball Assembly, and 62% versus 49% on Stir in Cup. The incremental benefit differs across tasks.
DexForce adaptation. Force-informed targets come from one successful demonstration per task and are tracked with Cartesian impedance. Its demonstration and initialization conditions differ.
Force magnitude alone does not characterize completion: DexForce’s lower mean thumb forces coincide with lower success and contact coverage. Simulation force statistics summarize trial-average positive-force magnitudes, including failed trials.